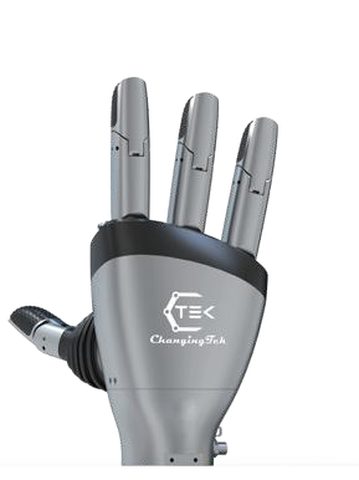
Lingsi Dexterous Four-Finger Hand
by ChangingTek · Taicang, Suzhou, Jiangsu · Dexterous hand series
Four-finger bionic hand with position, speed and force feedback.
Tell us the country, voltage and quantity. Our team in Austin and Bogotá checks certification, lead time and service with ChangingTek, then sends you a quote in USD.
English or Spanish · No cost to request · Quotes in USD
Full specifications
| Max travel distance | 80 mm |
|---|---|
| Drive method | Motor-driven |
| Max joint speed | 300 deg/s |
| Max recommended load | 2.5 kg (envelope) |
| Self-weight | 0.7 kg |
| Loudest noise | 60 dB |
| Max current | 1 A |
| Repeat positioning accuracy | +/-0.15 mm |
| Working voltage | 24 V |
| Max gripping force (per finger) | 6 N |
| Feedback parameters | Position, speed, force |
| Operating environment | 0~40 C, below 85%RH (without condensation) |
| Communication protocol | RS485 |
As printed in the ChangingTek catalog, page 33. Confirm final specs in your quote.
What it does well
- Integrated drive and control
- Precise control
- Long lifespan
- Low maintenance
Applications
Industries
More from ChangingTek
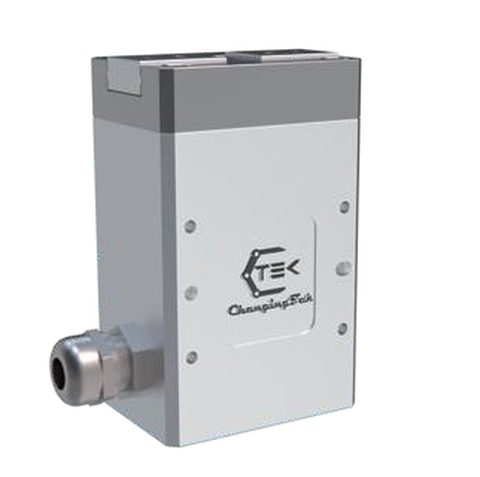
8S Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
0.1 kg0.2 lb payload
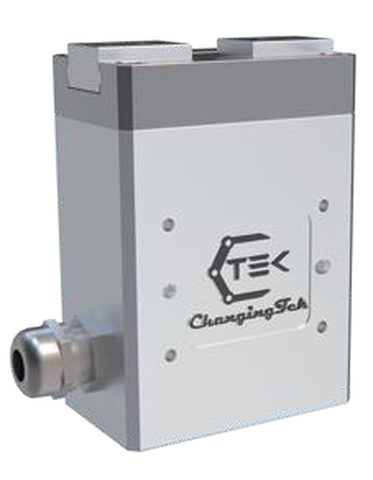
14S Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
0.2 kg0.4 lb payload
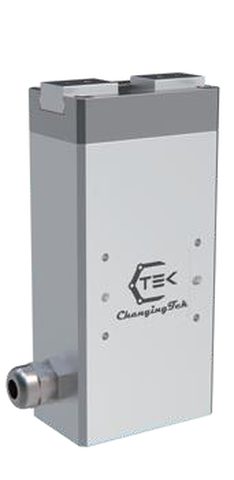
14 Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
0.4 kg0.9 lb payload
20 Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
0.5 kg1.1 lb payload
26 Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
1 kg2.2 lb payload
Compare with other makers
CasiaHand M6 Dexterous Hand
Robot joint · CasiaHand
10 kg22 lb payload
HT Series Linear Joint Module
3 sizesRobot joint · Zhidongli
IP40
CasiaHand M11 Dexterous Hand
Robot joint · CasiaHand
5 kg11 lb payload
HR Series Planetary Joint Module
2 sizesRobot joint · Zhidongli
IP40
CasiaHand X7 Dexterous Hand
Robot joint · CasiaHand
15 kg33 lb payload