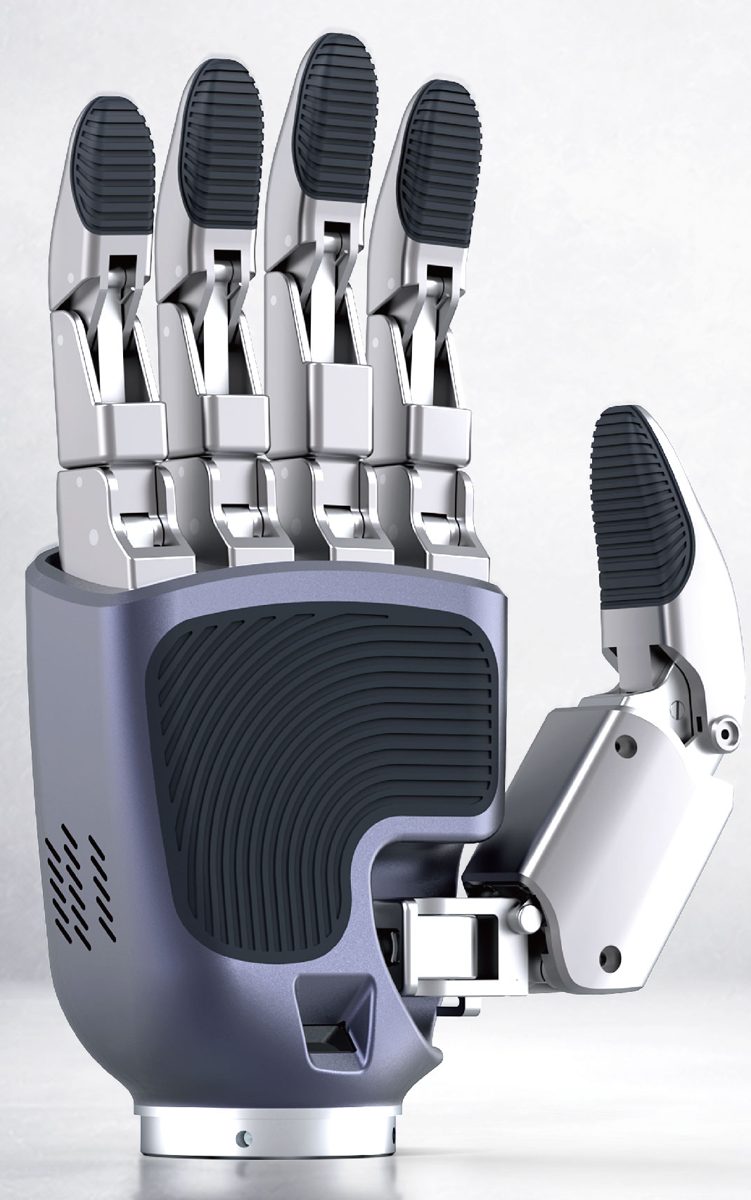
CasiaHand M6 Dexterous Hand
by CasiaHand · Nanjing, Jiangsu · CasiaHand
Ultra-compact five-finger robot hand with 6 actuators and 11 joints, weighing 410 g. Built for humanoid robots, research and data collection, with active fan cooling.
Tell us the country, voltage and quantity. Our team in Austin and Bogotá checks certification, lead time and service with CasiaHand, then sends you a quote in USD.
English or Spanish · No cost to request · Quotes in USD
Full specifications
| Degrees of freedom | 11 joints, 6 actuators |
|---|---|
| Payload | 10 kg |
| Weight | 410 g |
| Operating voltage | DC 24-48 V |
| Transmission | Worm gear and linkage |
| Minimum opening/closing time | 1 s |
| Minimum grasp diameter | 5 mm |
| Maximum fingertip force | 25 N |
| Communication interface | RS485 or FDCAN |
| Control mode | Hybrid force-position control |
| Temperature sensor | Infrared temperature measurement |
| Cooling method | Fan cooling |
| Tactile sensing (optional) | Fingertip tactile sensing |
| Height | 168 mm |
| Width | 73 mm |
As printed in the CasiaHand catalog, page 3. Confirm final specs in your quote.
What it does well
- Ultra-compact and lightweight
- Anthropomorphic design
- Multimodal sensing
- Active cooling system
Applications
Industries
More from CasiaHand
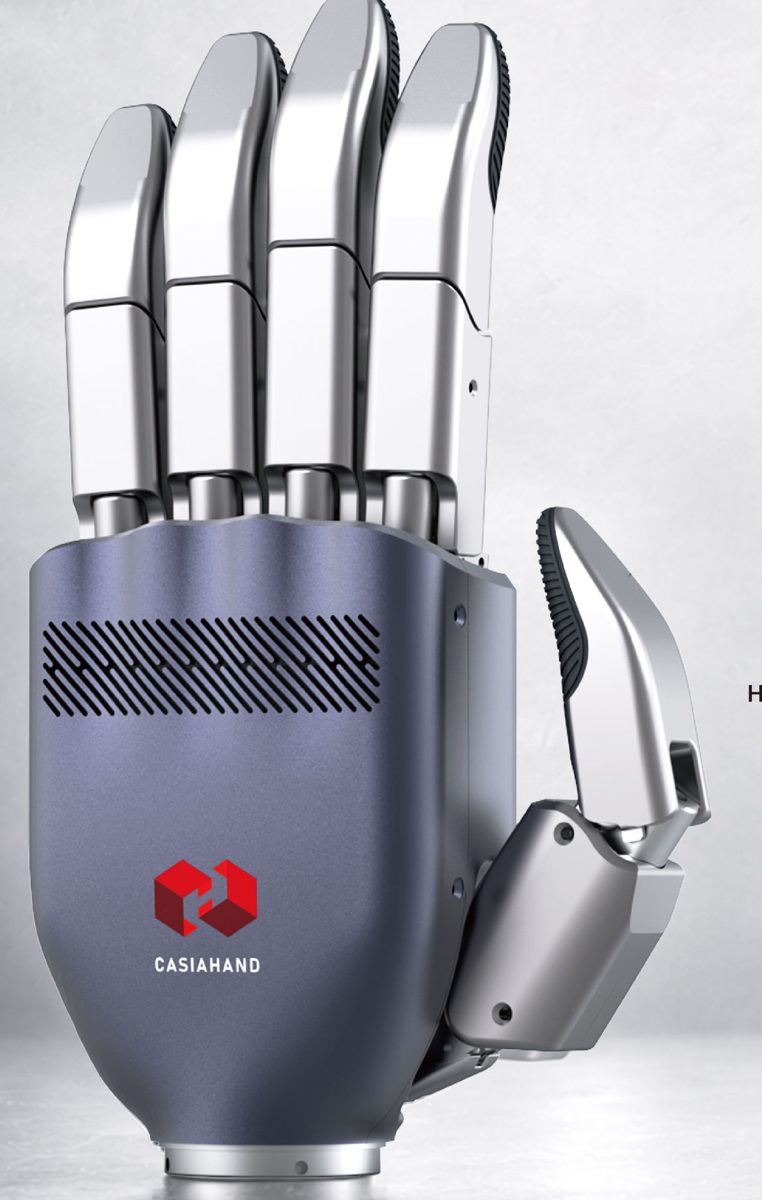
CasiaHand M11 Dexterous Hand
Robot joint · CasiaHand
5 kg11 lb payload
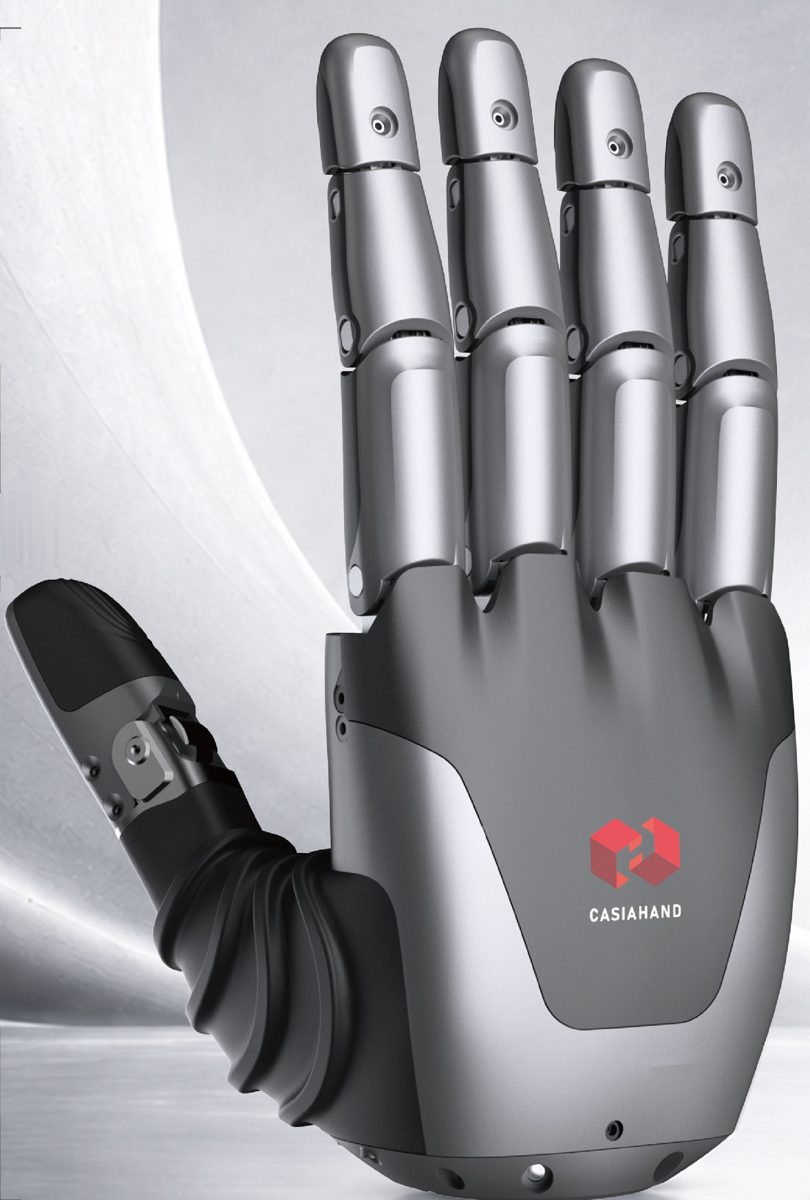
CasiaHand X7 Dexterous Hand
Robot joint · CasiaHand
15 kg33 lb payload
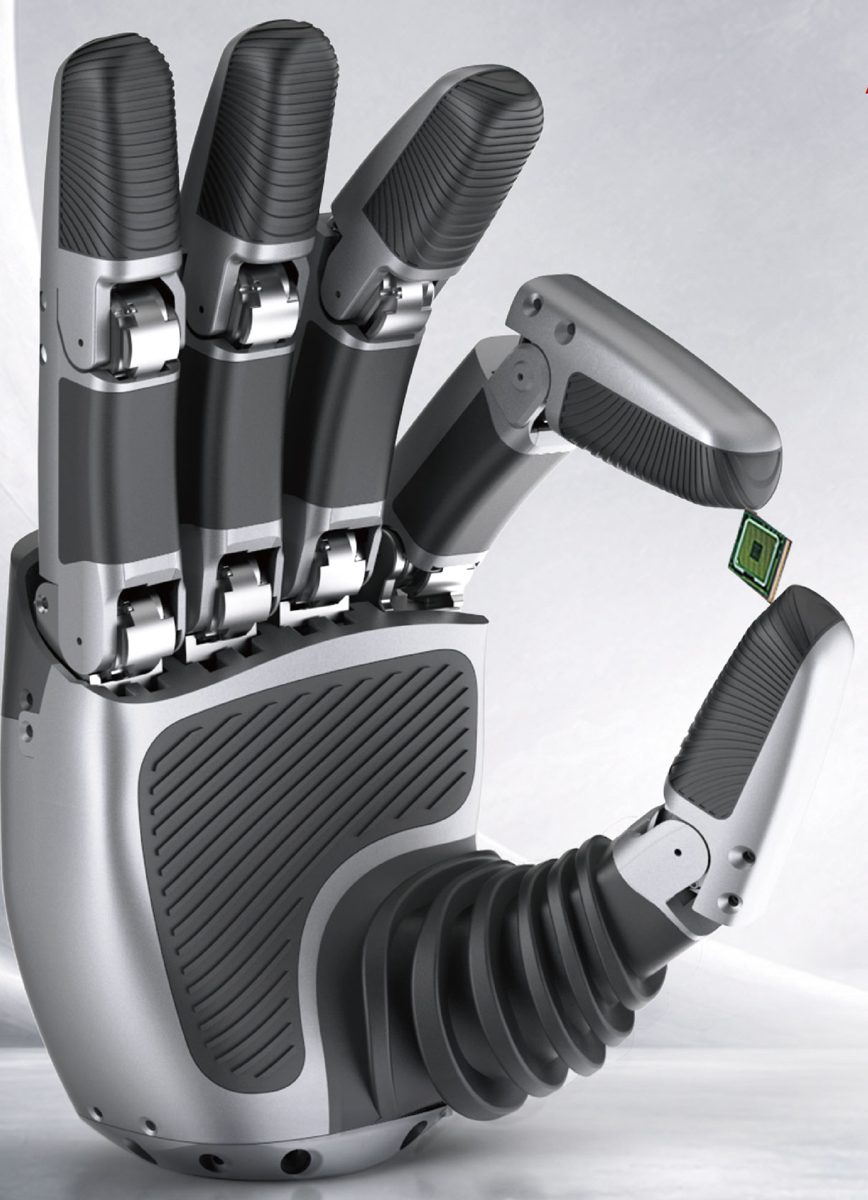
CasiaHand X12 Dexterous Hand
Robot joint · CasiaHand
30 kg66 lb payload
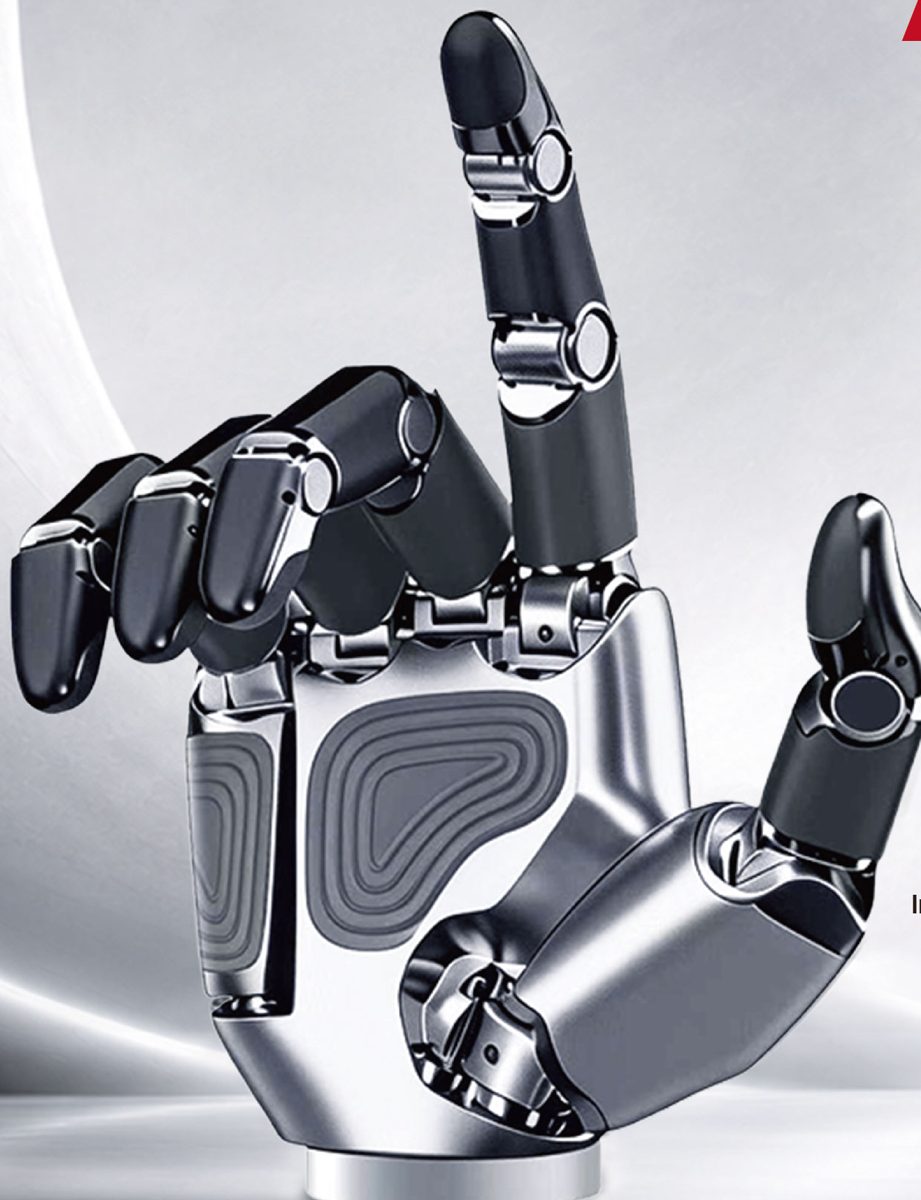
CasiaHand X21 Dexterous Hand
Robot joint · CasiaHand
15 kg33 lb payload
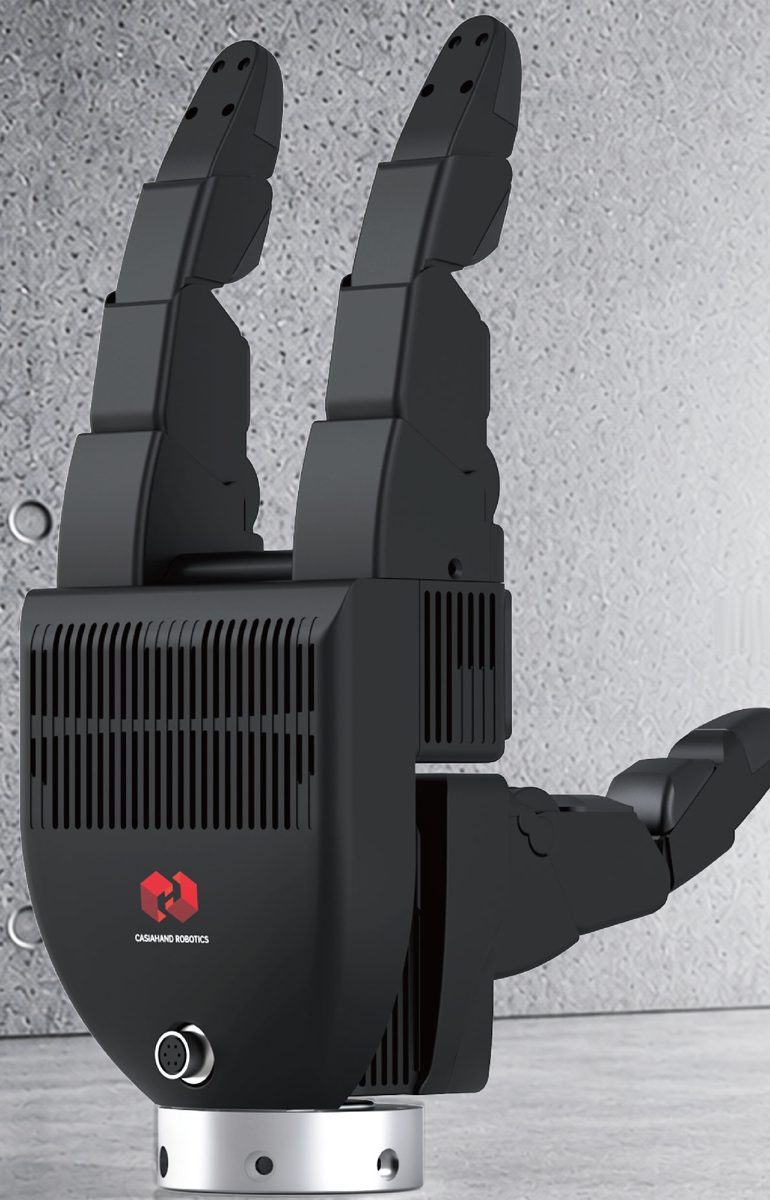
CasiaHand G4 Four-Actuator Hand
Robot joint · CasiaHand
5 kg11 lb payload
Compare with other makers
HT Series Linear Joint Module
3 sizesRobot joint · Zhidongli
IP40
HR Series Planetary Joint Module
2 sizesRobot joint · Zhidongli
IP40
HA Series Humanoid Arm
2 sizesRobot joint · Zhidongli
5 kg11 lb payload · 860 mm33.9 in reach · 7-axis
Gongshu Series Humanoid Robot
Robot joint · KAANH
200 kg441 lb payload · 1,323 mm52.1 in reach
Six-Axis Force/Torque Sensor
Robot joint · KAANH
Specs on request