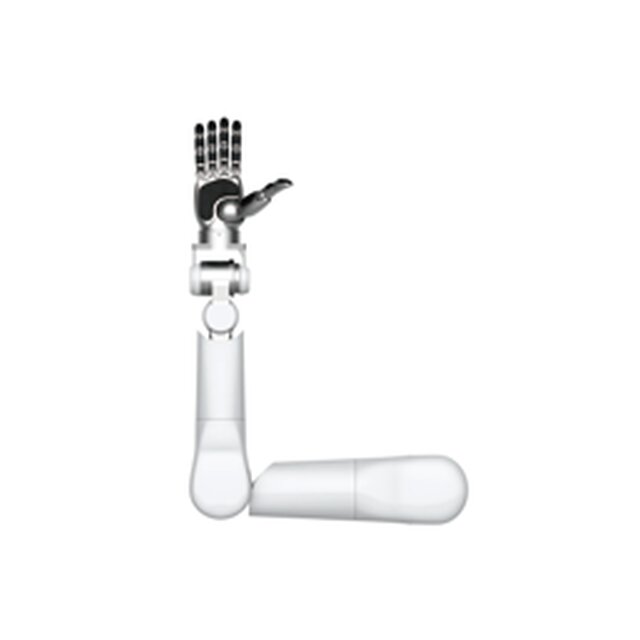
HA Series Humanoid Arm
by Zhidongli · Wuhan, Hubei (also Wuxi, Jiangsu) · HA series
7-DOF humanoid arms with 48 VDC, EtherCAT and impedance control (5 kg and 3 kg models), with ROS, Python and C++ development kits.
Tell us the country, voltage and quantity. Our team in Austin and Bogotá checks certification, lead time and service with Zhidongli, then sends you a quote in USD.
English or Spanish · No cost to request · Quotes in USD
Full specifications
| Model | HA7R-5S / HA7R-3N |
|---|---|
| Rated load (including end-effector) | 5 kg / 3 kg |
| Self-weight (excluding end-effector) | 12 kg / 6.5 kg |
| Maximum reach radius | 860 mm / 795 mm |
| Degrees of freedom | 7 |
| Average power consumption | Approx. 160 W / 105 W |
| Secondary development | ROS SDK, Python API, C++ API |
| Teaching method | Drag teaching, remote teaching |
| Mounting flange | 85 mm / 75 mm |
| Noise | ≤52 dB (at 1 m) |
| Communication | EtherCAT |
| Supply voltage | 48 VDC |
| Material | Aluminum alloy, nylon |
| Impedance control | Joint space and Cartesian space (HA7R-5S) |
| Force control (HA7R-5S) | Cartesian force-control error < 2 N |
| Repeatability (HA7R-5S) | ±0.1 mm |
| Joint encoder | Dual encoder |
| Operating modes | CST, CSV, CSP, PP, PD |
| End-effector (optional) | 7-DOF dexterous hand, gripper |
| Protection rating | IP40 |
| Controller | RK3588, 8 GB RAM, 64 GB ROM, Wanghuo real-time Linux |
As printed in the Zhidongli catalog, page 6. Confirm final specs in your quote.
What it does well
- Whole-arm self-collision protection
- Optional built-in joint force sensor (HA7R-5S)
- Drag teaching and remote teaching
Applications
Industries
Watch Zhidongli machines run
Filmed at the Zhidongli booth, CIIF 2026, Shanghai.
More from Zhidongli
HT Series Linear Joint Module
3 sizesRobot joint · Zhidongli
IP40
HR Series Planetary Joint Module
2 sizesRobot joint · Zhidongli
IP40
FA6R Desktop Arm
Cobot · Zhidongli
3 kg6.6 lb payload · 600 mm23.6 in reach · 6-axis
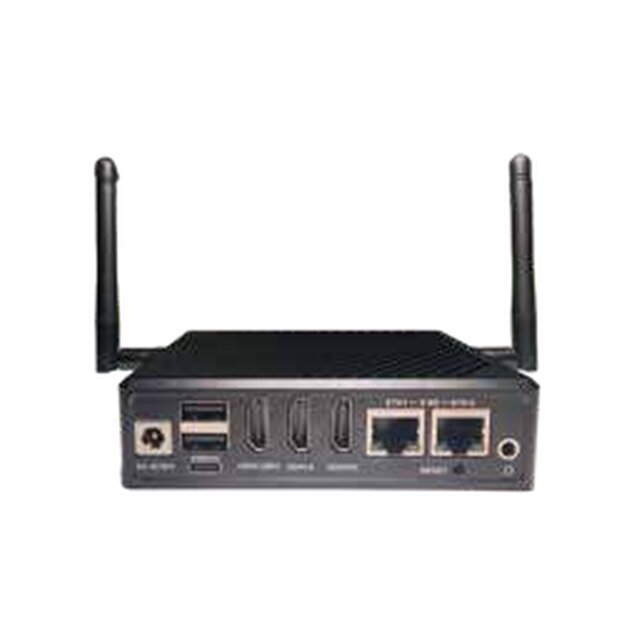
Yare Cerebellar Controller
Controller / IPC · Zhidongli
Specs on request
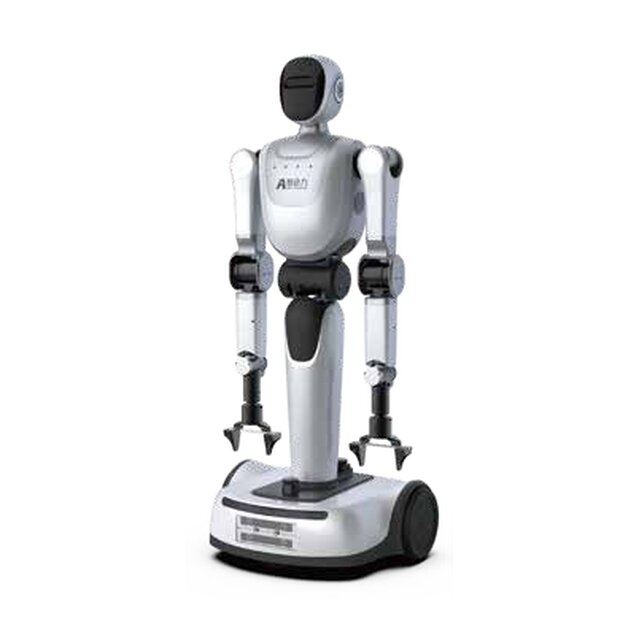
L1 Humanoid Wheeled Robot
Robot joint · Zhidongli
1.5 kg3.3 lb payload · 600 mm23.6 in reach
Compare with other makers
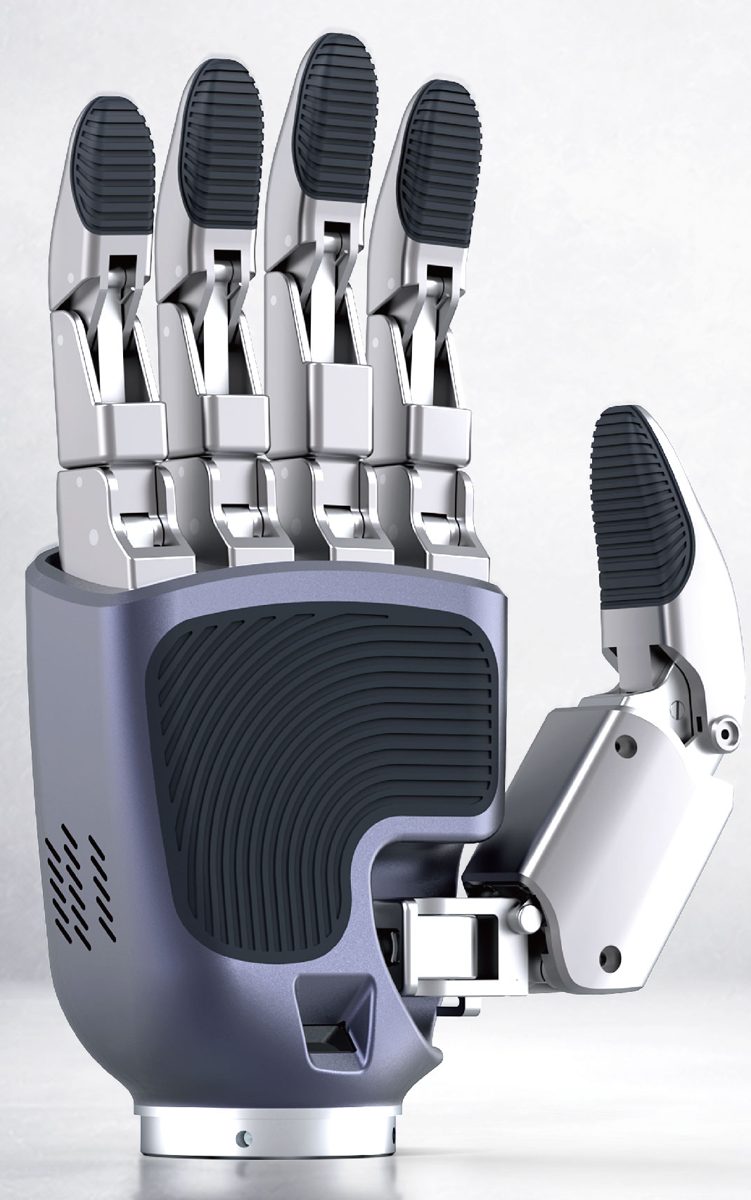
CasiaHand M6 Dexterous Hand
Robot joint · CasiaHand
10 kg22 lb payload
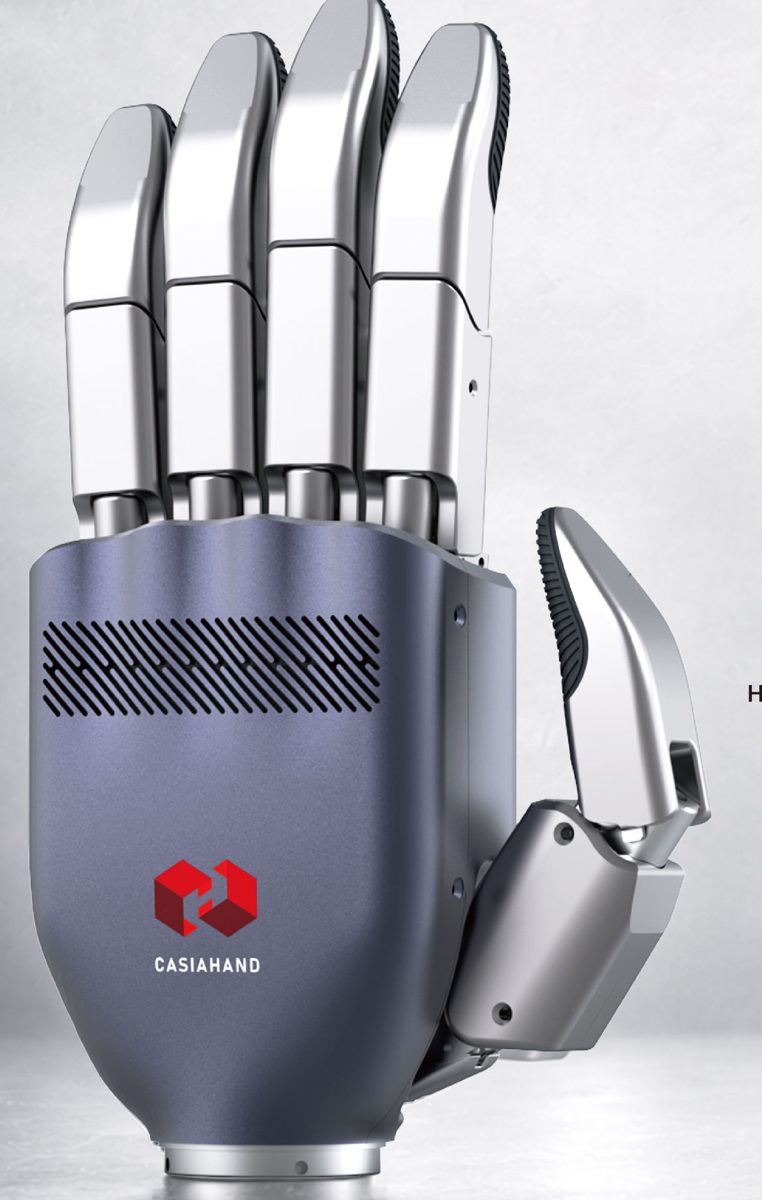
CasiaHand M11 Dexterous Hand
Robot joint · CasiaHand
5 kg11 lb payload
CasiaHand X7 Dexterous Hand
Robot joint · CasiaHand
15 kg33 lb payload
CasiaHand X12 Dexterous Hand
Robot joint · CasiaHand
30 kg66 lb payload
Gongshu Series Humanoid Robot
Robot joint · KAANH
200 kg441 lb payload · 1,323 mm52.1 in reach