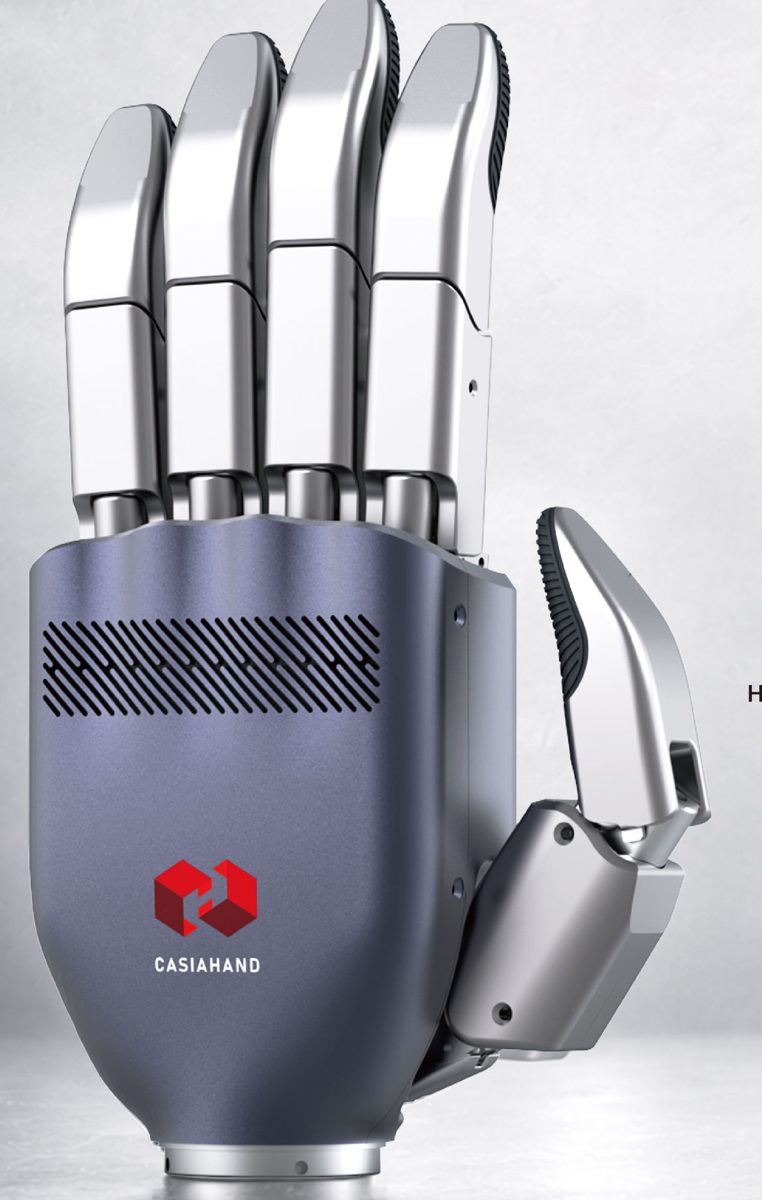
CasiaHand M11 Dexterous Hand
by CasiaHand · Nanjing, Jiangsu · CasiaHand
Eleven-actuator humanoid hand with a hybrid rigid-compliant control scheme and fan cooling. Opens and closes in 0.6 s with a 5 kg payload.
Tell us the country, voltage and quantity. Our team in Austin and Bogotá checks certification, lead time and service with CasiaHand, then sends you a quote in USD.
English or Spanish · No cost to request · Quotes in USD
Full specifications
| Degrees of freedom | 11 joints, 11 actuators |
|---|---|
| Payload | 5 kg |
| Weight | 645 g |
| Operating voltage | DC 24-48 V |
| Transmission | Worm gear and tendon |
| Minimum opening/closing time | 0.6 s |
| Minimum grasp diameter | 5 mm |
| Maximum fingertip force | 15 N |
| Communication interface | RS485 + FDCAN |
| Control mode | Hybrid force-position control |
| Tactile sensor | 8 x 6 array tactile sensor (optional) |
| Cooling method | Fan cooling |
| Tactile sensing (optional) | Fingertip tactile sensing |
| Height | 208 mm |
| Width | 83 mm |
As printed in the CasiaHand catalog, page 4. Confirm final specs in your quote.
What it does well
- Anthropomorphic design
- Hybrid rigid-compliant control
- Active cooling system
Applications
Industries
More from CasiaHand
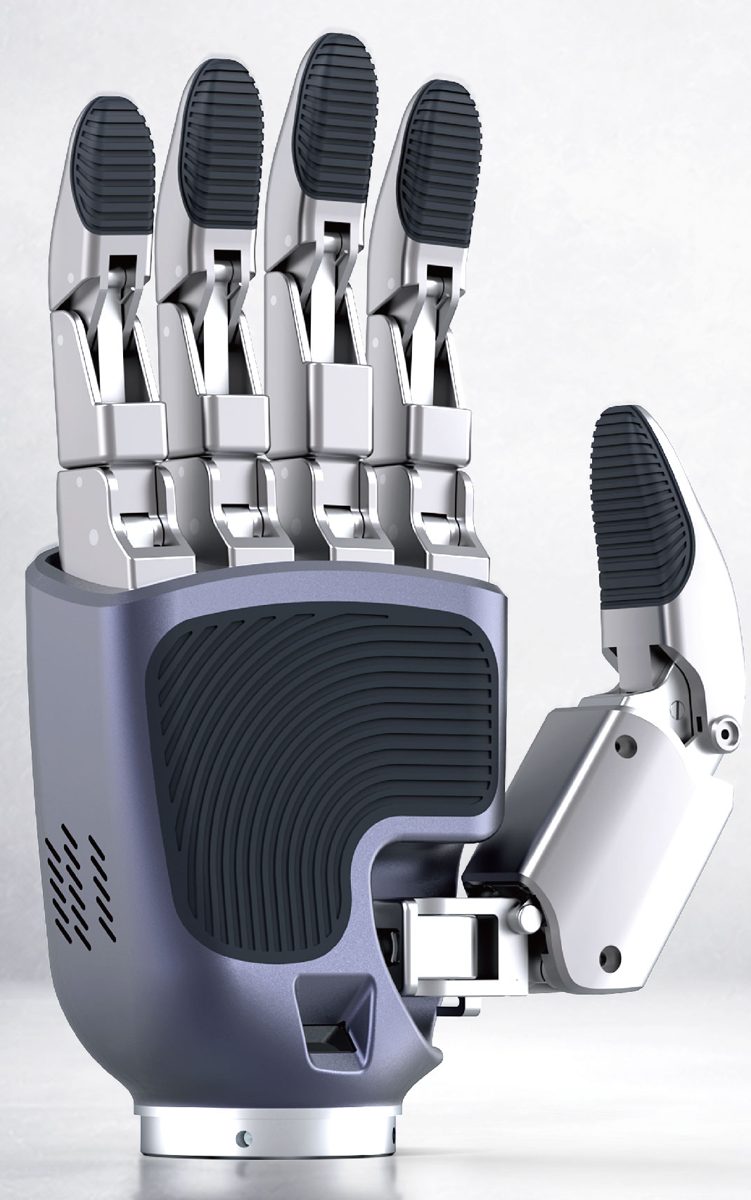
CasiaHand M6 Dexterous Hand
Robot joint · CasiaHand
10 kg22 lb payload
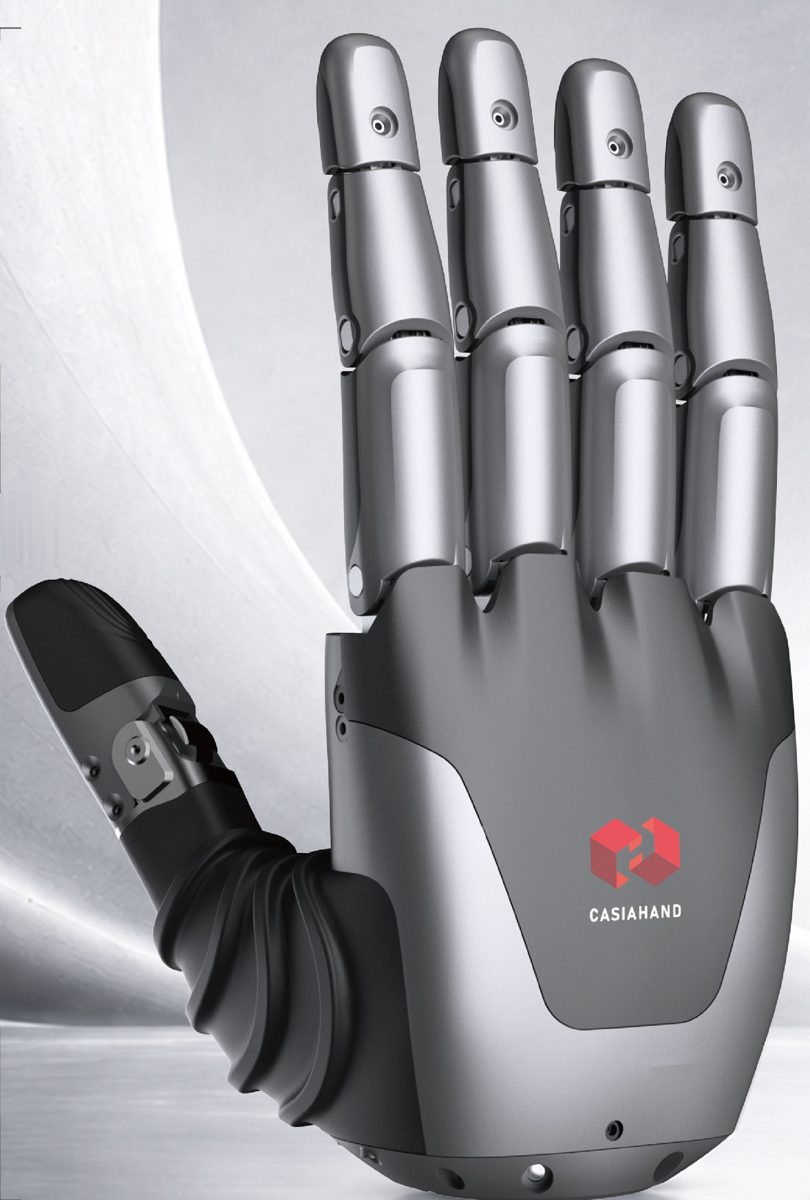
CasiaHand X7 Dexterous Hand
Robot joint · CasiaHand
15 kg33 lb payload
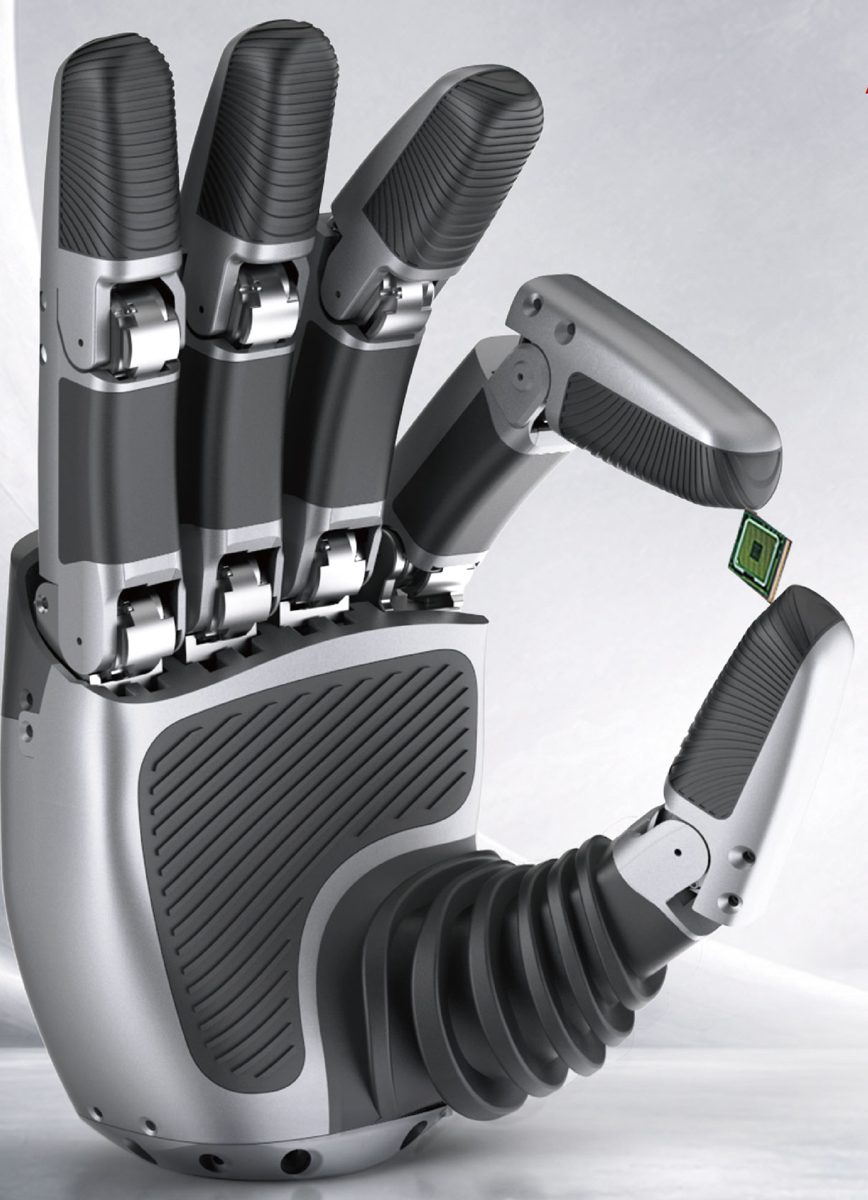
CasiaHand X12 Dexterous Hand
Robot joint · CasiaHand
30 kg66 lb payload
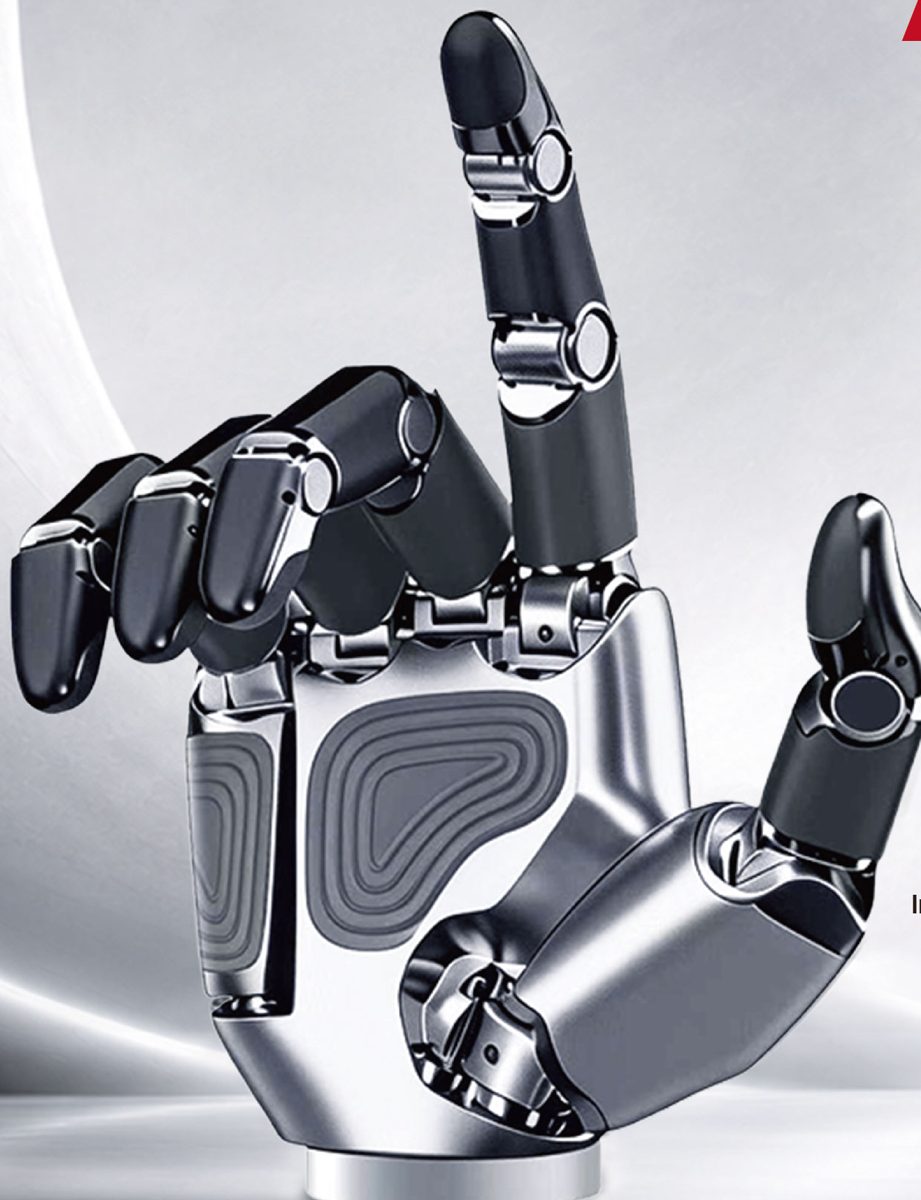
CasiaHand X21 Dexterous Hand
Robot joint · CasiaHand
15 kg33 lb payload
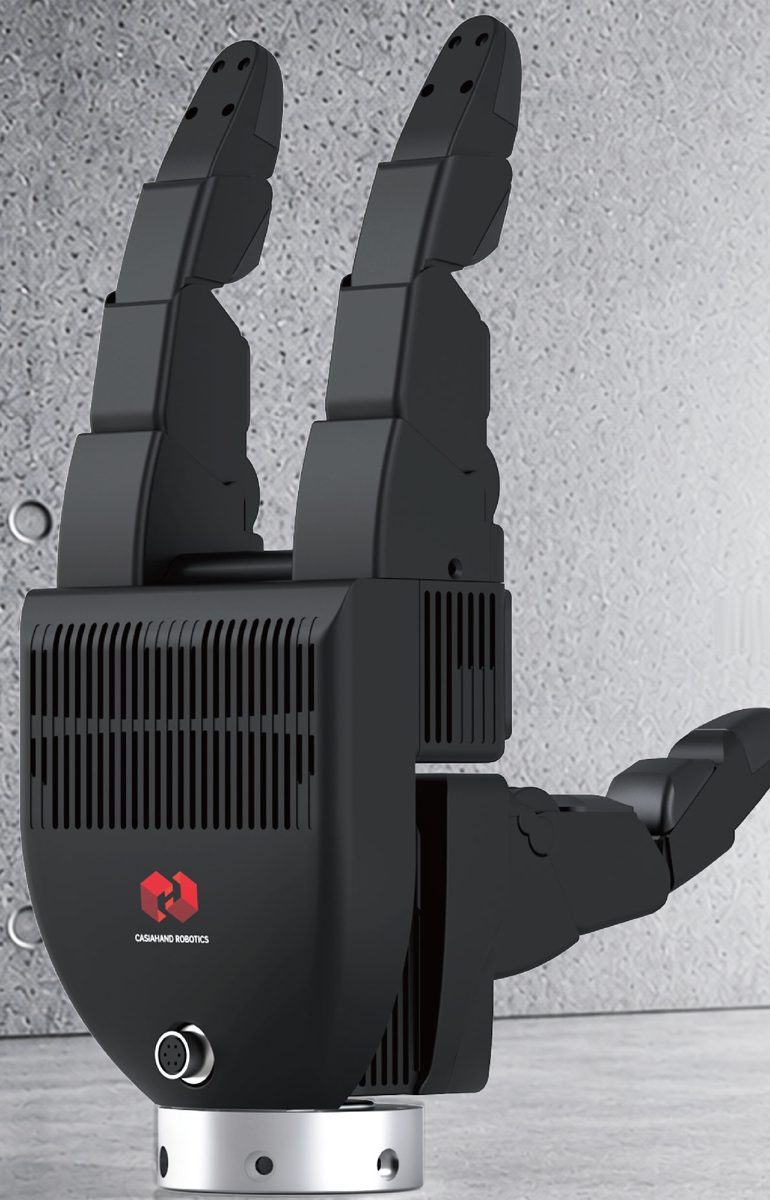
CasiaHand G4 Four-Actuator Hand
Robot joint · CasiaHand
5 kg11 lb payload
Compare with other makers
HT Series Linear Joint Module
3 sizesRobot joint · Zhidongli
IP40
HR Series Planetary Joint Module
2 sizesRobot joint · Zhidongli
IP40
HA Series Humanoid Arm
2 sizesRobot joint · Zhidongli
5 kg11 lb payload · 860 mm33.9 in reach · 7-axis
Gongshu Series Humanoid Robot
Robot joint · KAANH
200 kg441 lb payload · 1,323 mm52.1 in reach
Six-Axis Force/Torque Sensor
Robot joint · KAANH
Specs on request