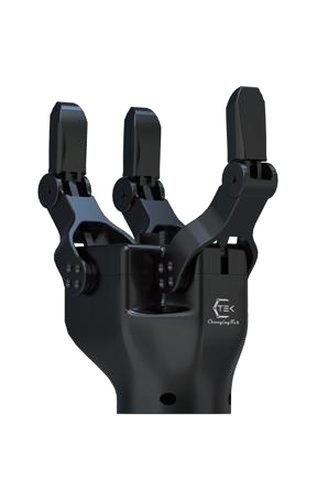
Gripping Three-Finger Hand
by ChangingTek · Taicang, Suzhou, Jiangsu · Dexterous hand series
Three-finger bionic gripping hand with 50 N force for irregular parts.
Tell us the country, voltage and quantity. Our team in Austin and Bogotá checks certification, lead time and service with ChangingTek, then sends you a quote in USD.
English or Spanish · No cost to request · Quotes in USD
Full specifications
| Drive method | Motor-driven |
|---|---|
| Stroke | 60 mm |
| Max gripping force | 50 N |
| Max recommended load | 1.5 kg |
| Max current | 4.5 A |
| Max gripping speed | 100 mm/s |
| Working voltage | 24 V |
| Repeat positioning accuracy | +/-0.03 mm |
| Opening/closing time | 0.6 s |
| Self-weight | 1.1 kg |
| Operating environment | 0~40 C, below 85%RH (without condensation) |
| Communication protocol | RS485+IO |
As printed in the ChangingTek catalog, page 31. Confirm final specs in your quote.
What it does well
- Integrated drive and control
- Modular design
- Independent control
Applications
Industries
More from ChangingTek
8S Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
0.1 kg0.2 lb payload
14S Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
0.2 kg0.4 lb payload
14 Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
0.4 kg0.9 lb payload
20 Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
0.5 kg1.1 lb payload
26 Parallel Two-Finger Gripper
Gripper / EOAT · ChangingTek
1 kg2.2 lb payload
Compare with other makers
CasiaHand M6 Dexterous Hand
Robot joint · CasiaHand
10 kg22 lb payload
HT Series Linear Joint Module
3 sizesRobot joint · Zhidongli
IP40
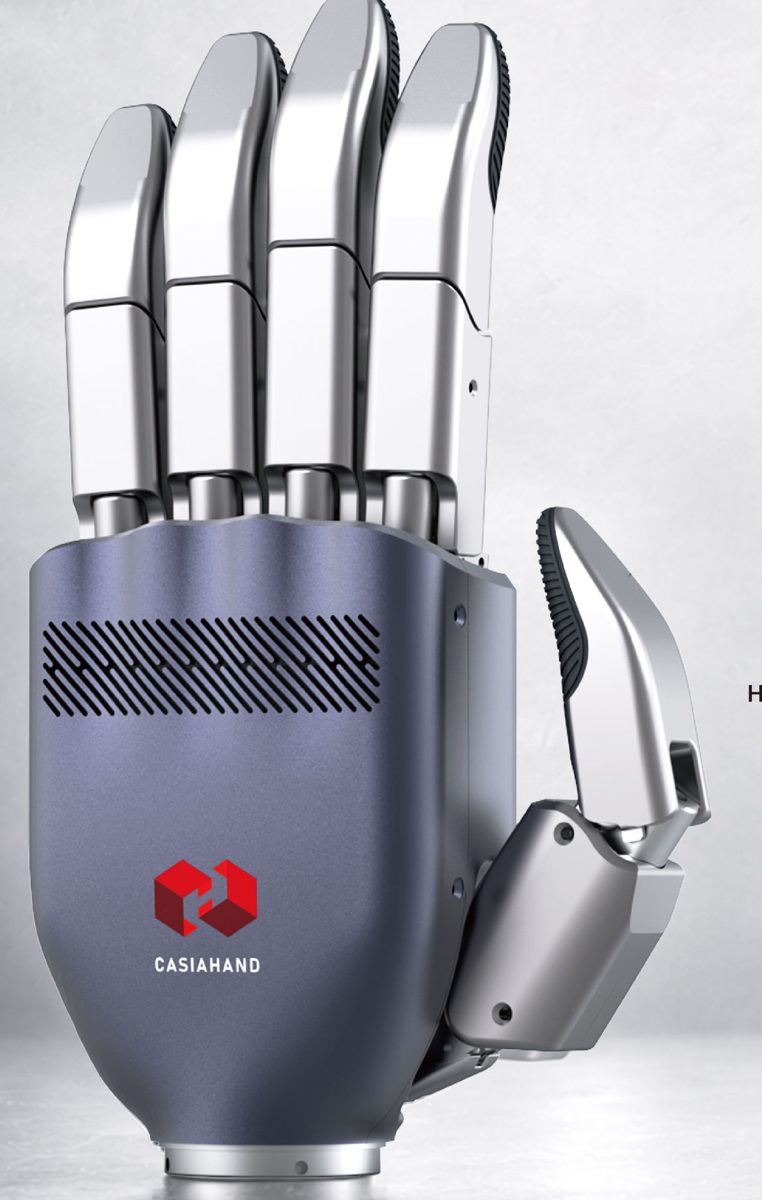
CasiaHand M11 Dexterous Hand
Robot joint · CasiaHand
5 kg11 lb payload
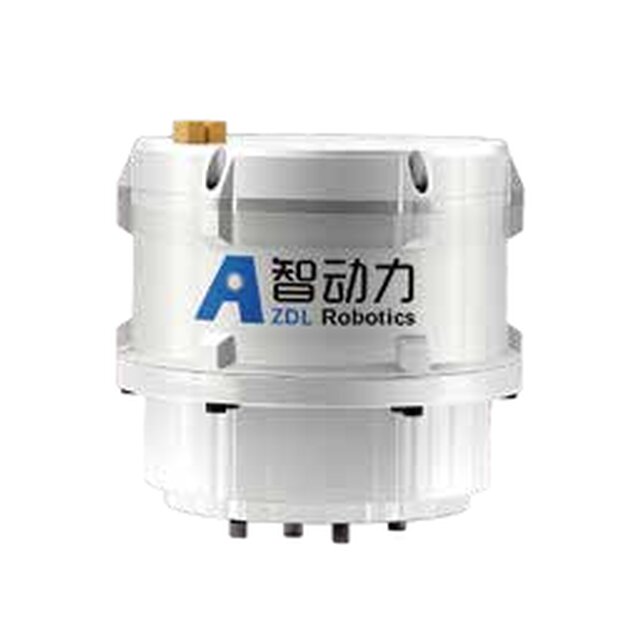
HR Series Planetary Joint Module
2 sizesRobot joint · Zhidongli
IP40
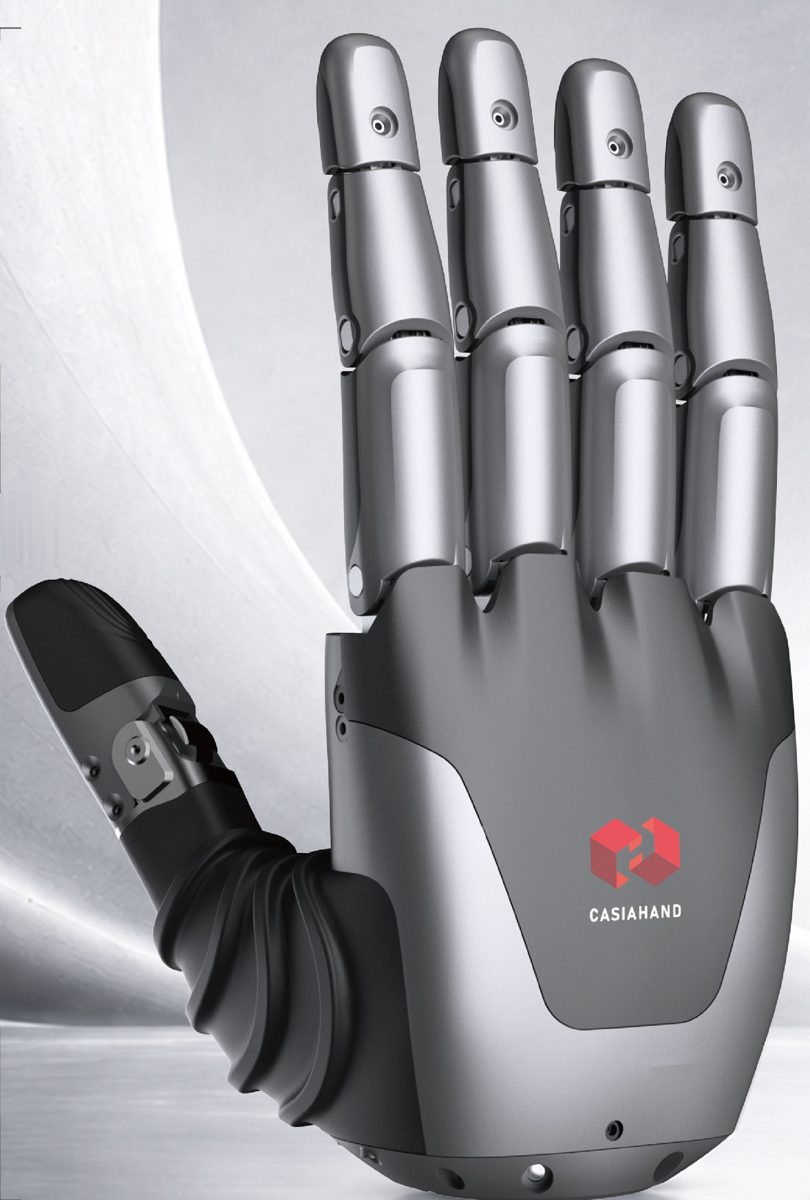
CasiaHand X7 Dexterous Hand
Robot joint · CasiaHand
15 kg33 lb payload